October 21-22, Lund University
Please note that the program is still subject to change.
Program Workshop
October 21 (day 1)
09:30 - 10:30
Registration and coffee
10:30 - 10:50
Opening and News from ELLIIT
Erik G. Larsson (ELLIIT director), Yiannis Karayiannidis (Workshop chair)
10.50 - 11.30
Keynote: Shaping the Future of Human-Robot Collaboration
Chair: Yiannis Karayiannidis (LU)
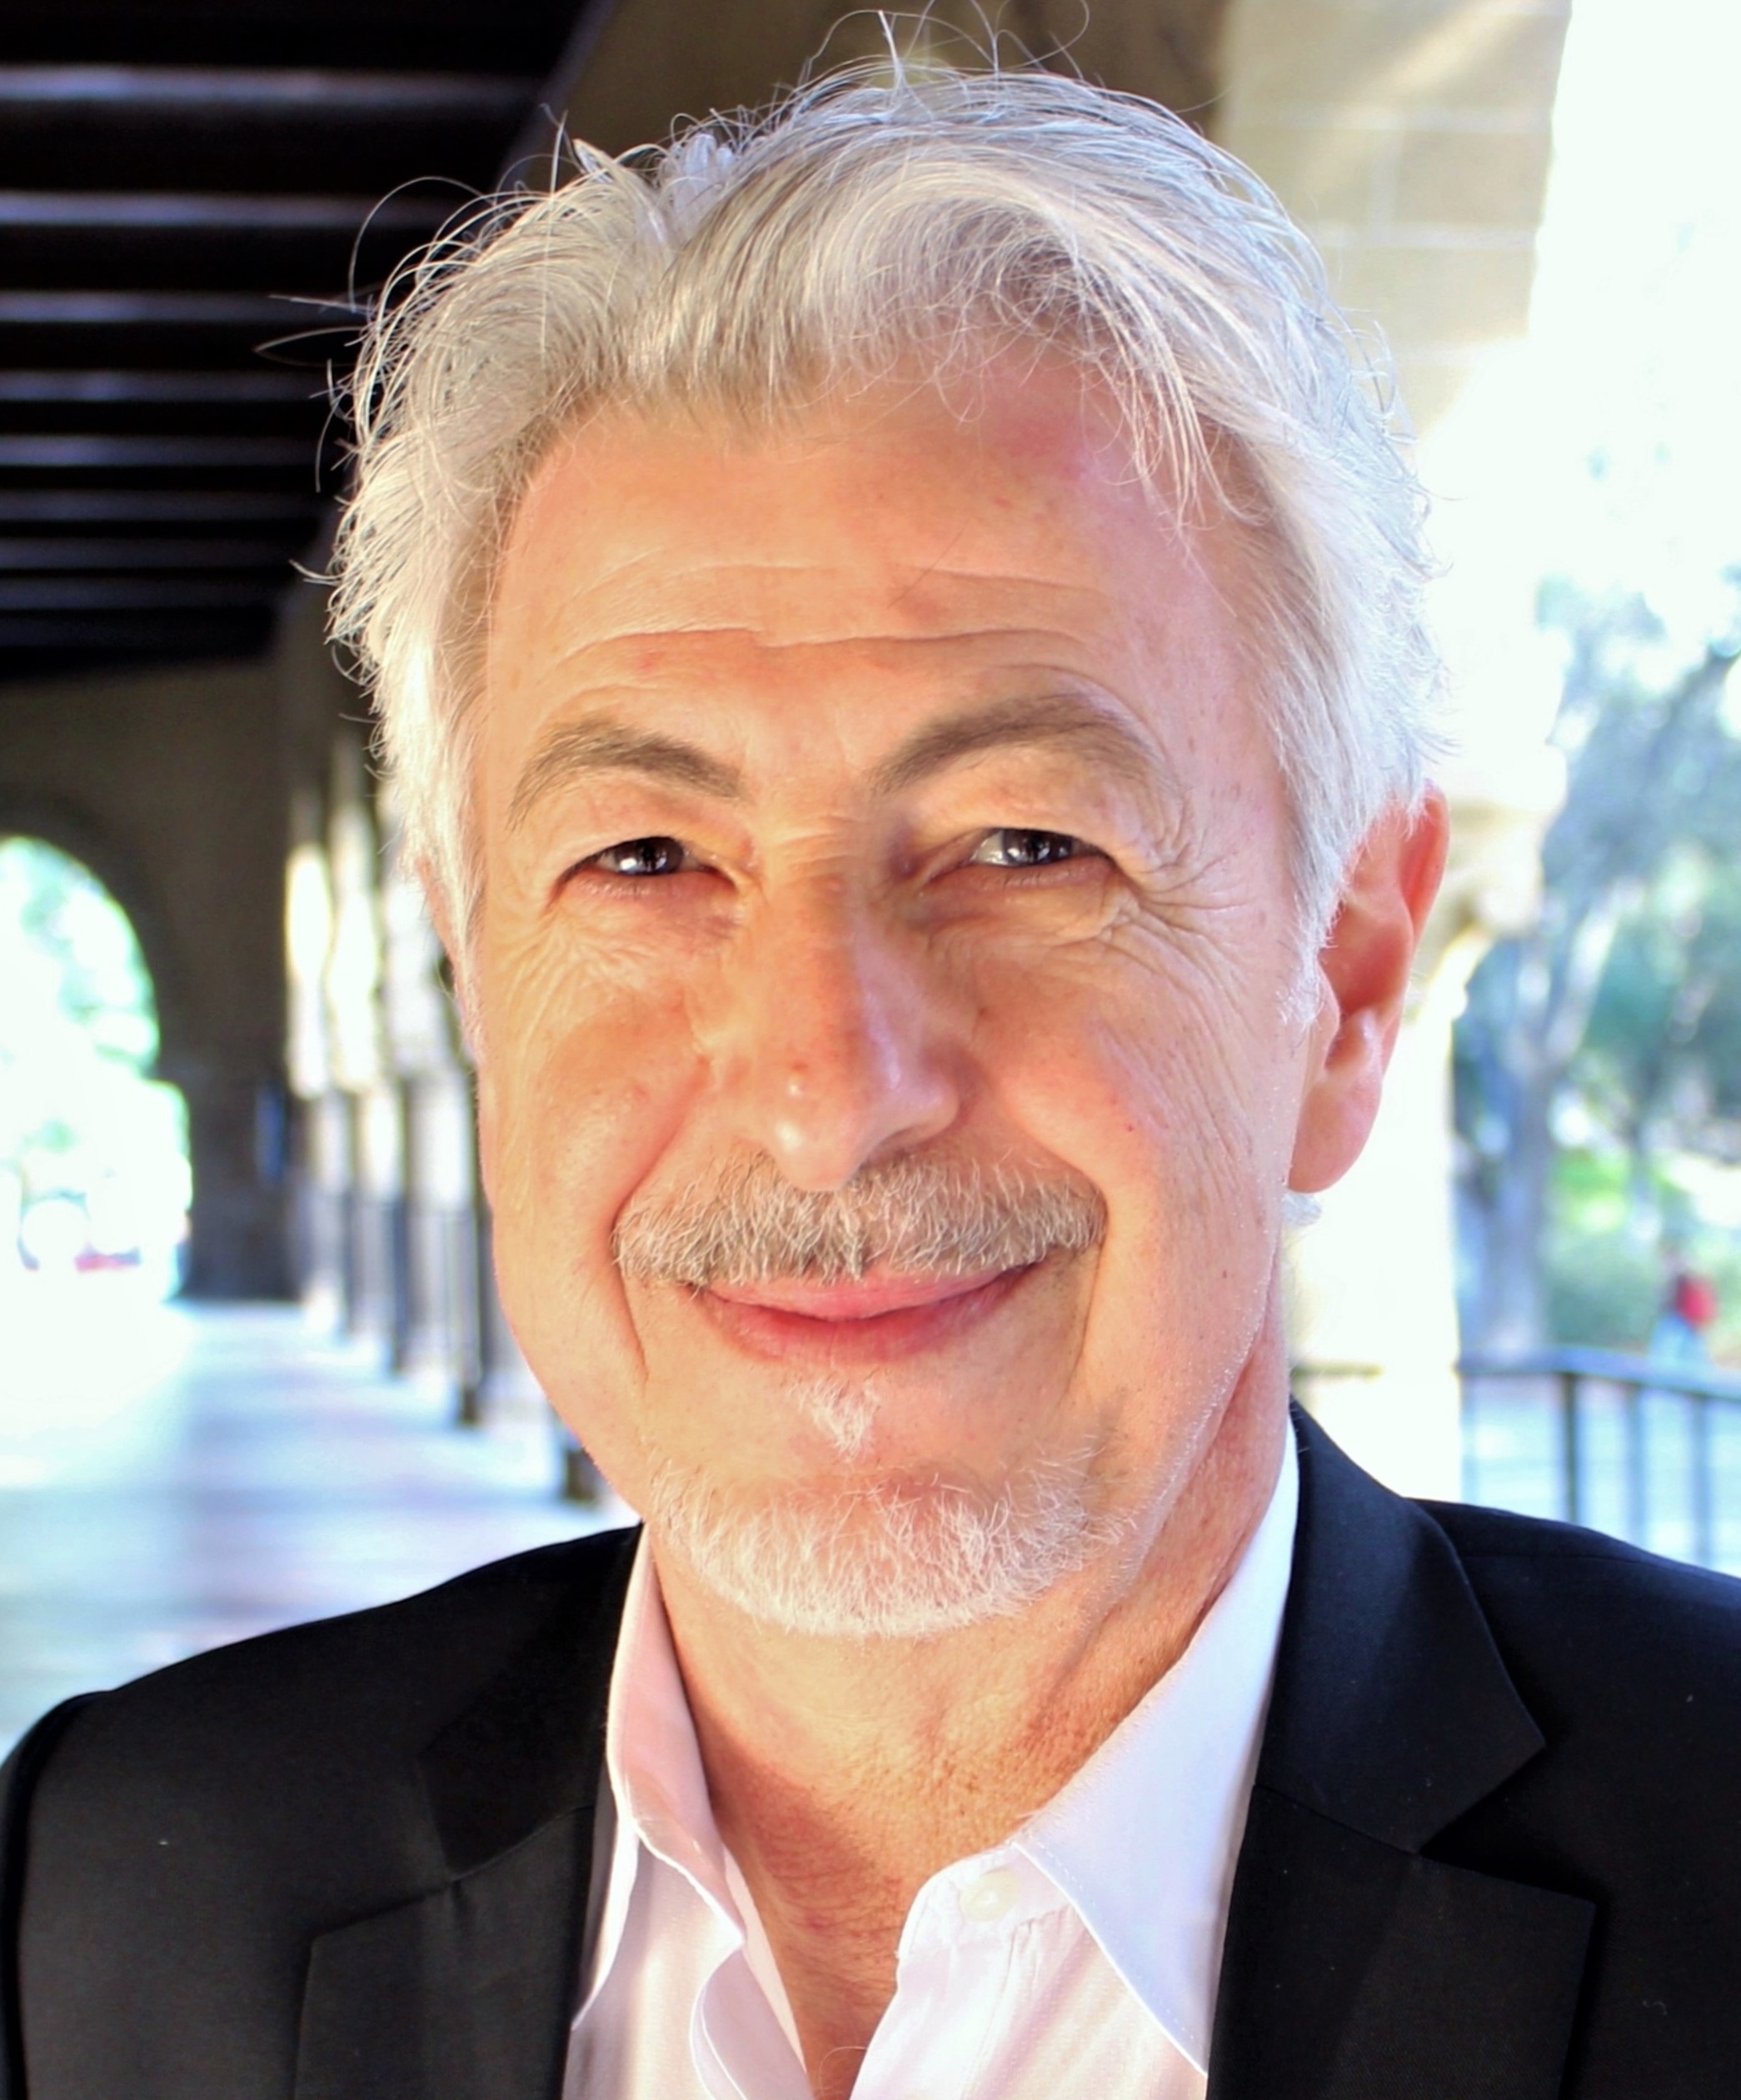
Oussama Khatib, Stanford University
Oussama Khatib received his PhD from Sup’Aero, Toulouse, France, in 1980. He is Professor of Computer Science at Stanford University and Director of the Stanford Robotics Center (SRC). He is a recipient of an honorary doctorate from the University of Montpellier.
His research focuses on methodologies and technologies in human-centered robotics, haptic interactions, artificial intelligence, and human motion synthesis. Professor Khatib is President of the International Foundation of Robotics Research (IFRR) and an IEEE Fellow. He is Editor of the Springer STAR and SPAR series, Springer Handbook of Robotics, and Springer Encyclopedia of Robotics. He is a recipient of the IEEE Robotics and Automation, Pioneering Award, the George Saridis Leadership Award, and the Distinguished Service Award. Professor Khatib is recipient of the Japan Robot Association (JARA) Award, the Rudolf Kalman Award, and the IEEE Technical Field Award. He is Knight of the French National Order of Merit and a member of the United Sates National Academy of Engineering. Professor Khatib is recipient of the 2024 Great Arab Minds Award.
Abstract
Central to our efforts in robotics is a strong focus on human-robot collaboration — an area where robotics can profoundly extend human capabilities, especially in environments that are hazardous, remote, or otherwise inaccessible. By physically distancing humans from danger while still enabling their skills, intuition, and experience to guide robotic systems, we aim to redefine the future of work and remote operations.
A striking example of this vision is OceanOneK, a state-of-the-art robotic diver developed at Stanford. Equipped with advanced autonomous capabilities for physical interaction and a sophisticated haptic/stereovision interface, OceanOneK allows human experts to intuitively control and collaborate with the robot in real time. During a series of archaeological expeditions in the Mediterranean, OceanOneK successfully operated at extreme depths, demonstrating how the fusion of human cognition and robotic precision can unlock unprecedented exploration and intervention capabilities. These developments illustrate the powerful synergy made possible through human-robot collaboration. From accessing new natural resources and delivering medical care in remote regions, to maintaining distant infrastructure and executing disaster response in extreme environments — whether deep underwater, underground, atop mountains,or in space – robotics research is pushing the boundaries of what’s possible.
11:30 – 12:35
ELLIIT Recruited Faculty
(4 x 15 min each)
Chair: Håkan Grahn (BTH)
Khac-Hoang Ngo (LiU):
Communicating what is needed, and just that
Diana Osorio (LiU):
Beyond Connectivity: Networks that sense, protect,
and adapt
Sara Willhammar (LU):
On the search of a rare species
Edison Pignaton de Freitas (HH):
Game of Drones” on the Internet of Battle Things
12:35 – 14:00
Lunch
14:00 – 15:50
Poster Session with coffee and something sweet
16:00 – 17:00
ELLIIT and impact on industry
Moderated panel discussions with representatives from ELLIIT academia, industry, and ELLIIT alumni.
Moderator:
Magnus Frodigh, Ericsson
Panel:
18:00
Dinner
October 22 (day 2)
09:00 – 10:15
E:A
E-building
Highlight talks
(4 x 15 min each)
Chair: Edison Pignaton de Freitas (HH)
Görel Hedin (LU), Cloud Tooling for Large-Scale Cyber-Physical System Model-Based Development
Per-Erik Forssén (LiU), Situation Aware Perception for Safe Autonomous Robotics Systems
Håkan Grahn (BTH), GPAI – General Purpose AI Computing
Ingrid Hotz (LiU), Visual Feature Based Data Reduction
10:15 – 10:40
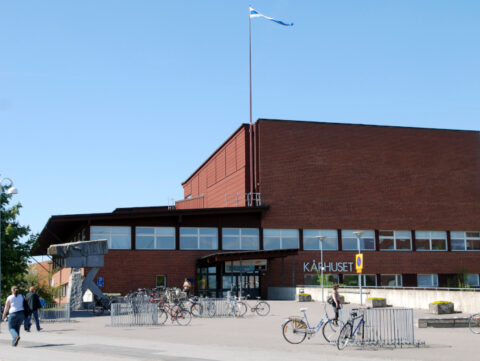
Kårhusets Aula
Coffee and Sandwiches
10:45– 12:00
kårhusets aula
Highlight talks
(4 x 15 min each)
Chair: Farnaz Adib Yaghmaie (LiU)
Simin Nadjm-Tehrani (LiU), 5G/6G Security
Wojciech Mostowski (HH), Static Analysis of Energy Usage in Software
Elina Rönnberg (LiU), Discrete optimisation for automatic decision-making in large-scale complex systems
Michael Doggett (LU), Real-Time Realistic Pixel Synthesis using Deep Learning for Augmented and Virtual Reality
12:00 – 13:00
Moroten & Piskan
Lunch
13:15 – 15:00
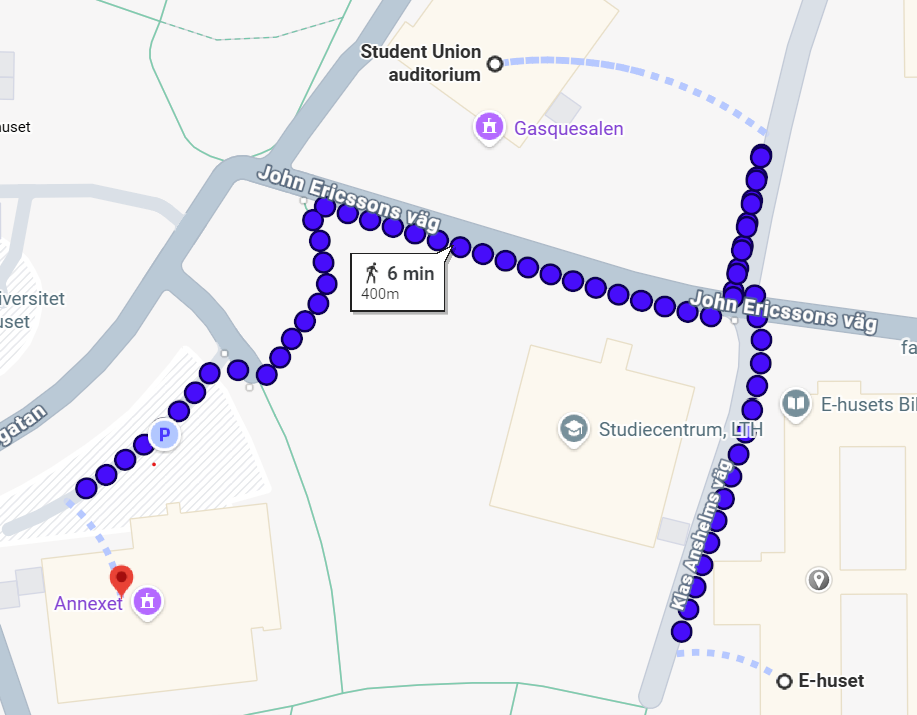
Annexet
Parallel Mini Workshops
Coffee, buns and water at 14:00. Mini workshop venues are in the building Math Annex
Resource-Efficient AI and AI Accelerators
Organizers: Amir Aminifar (LU) and Christoph Kessler (LiU)
Venue: MA1
Agenda
Neuromorphic computing – A path to energy-efficient AI systems
Efficient AI through analog in-memory computing
Empowering AI through efficient and scalable hardware design
Precision emiualtion in AI accelerators
Venue: MA2
Agenda
Cooperative driving: How to brake and when to cross
Real-time tracking of Markov chains over wireless channels
A view on wireless in the loop
Lyapunov optimization for resource allocation in communication networks
AI meets Autonomous Vehicles
Organizers: Eren Aksoy (LU) and Cristofer Englund (HH)
Venue: MA4
Agenda
- Amer Mustajbasic, Zenseact
- Per-Erik Forssén (LiU): Collision Risk Estimation via Loss Prediction in End-to-End Autonomous Driving
- Alexandros Sopasakis (LU): Learning the Unexpected: Detecting Traffic Anomalies with Generative AI
Advancing gender equality and diversity in STEM: the ELLIIT initiative
Organizer: Charlotta Johnsson (LU) and Kaan Bür (LU)
Venue: MA3
Agenda
The measure of our humanity: What can we learn about humans by engaging with social robots?
Women in mathematics
Reflections on PhD life as a woman in electrical engineering